Selected Work
Projects
A collection of engineering case studies documenting competitive robots, CAD models, and mechanical builds—from first concept to competition-ready machine.
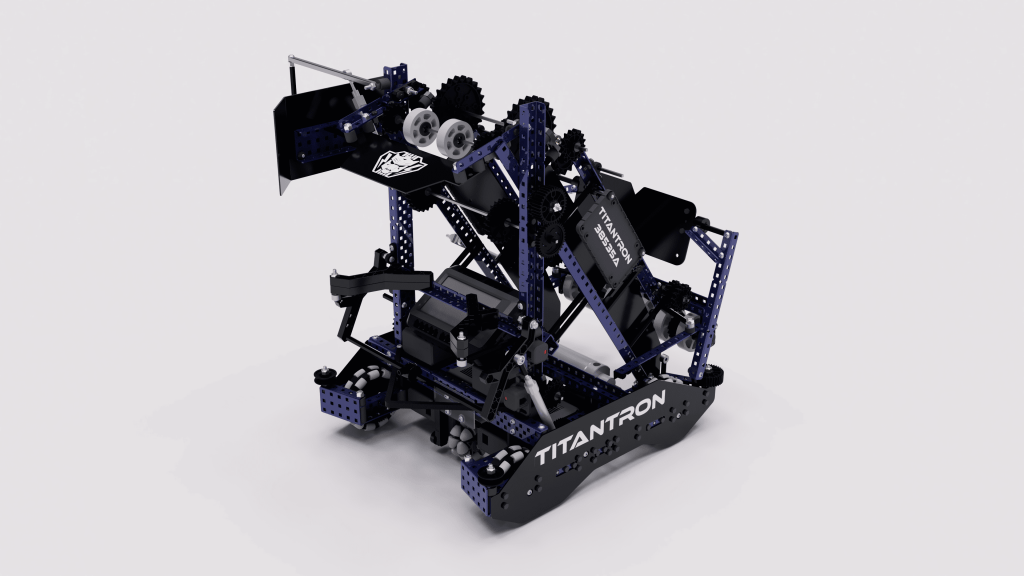
Robotics
vex push back
A competition robot built for VEX Pushback, designed around high-speed intake and efficient ball management. Iterated through multiple prototypes to optimize scoring consistency under match pressure.
2026
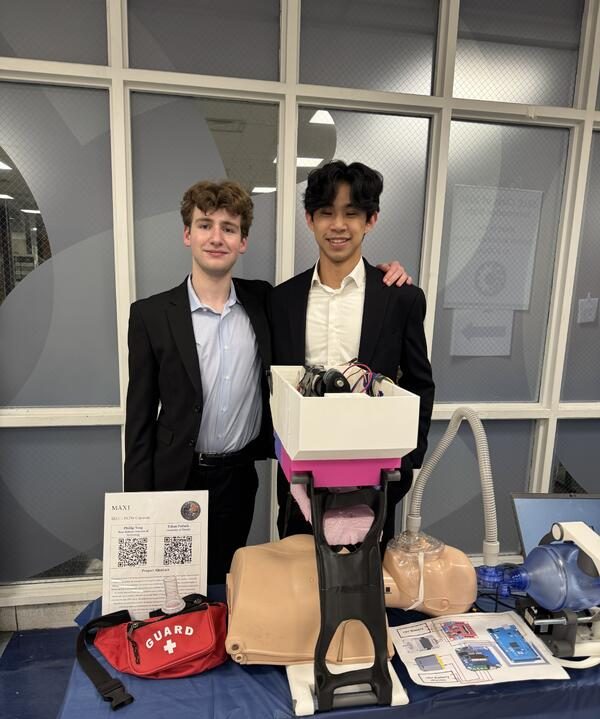
cad design
MAx1
A mechanically actuated CPR training device designed to simulate chest compressions at correct depth and rate. Built to give students realistic feedback during CPR practice sessions.
2026
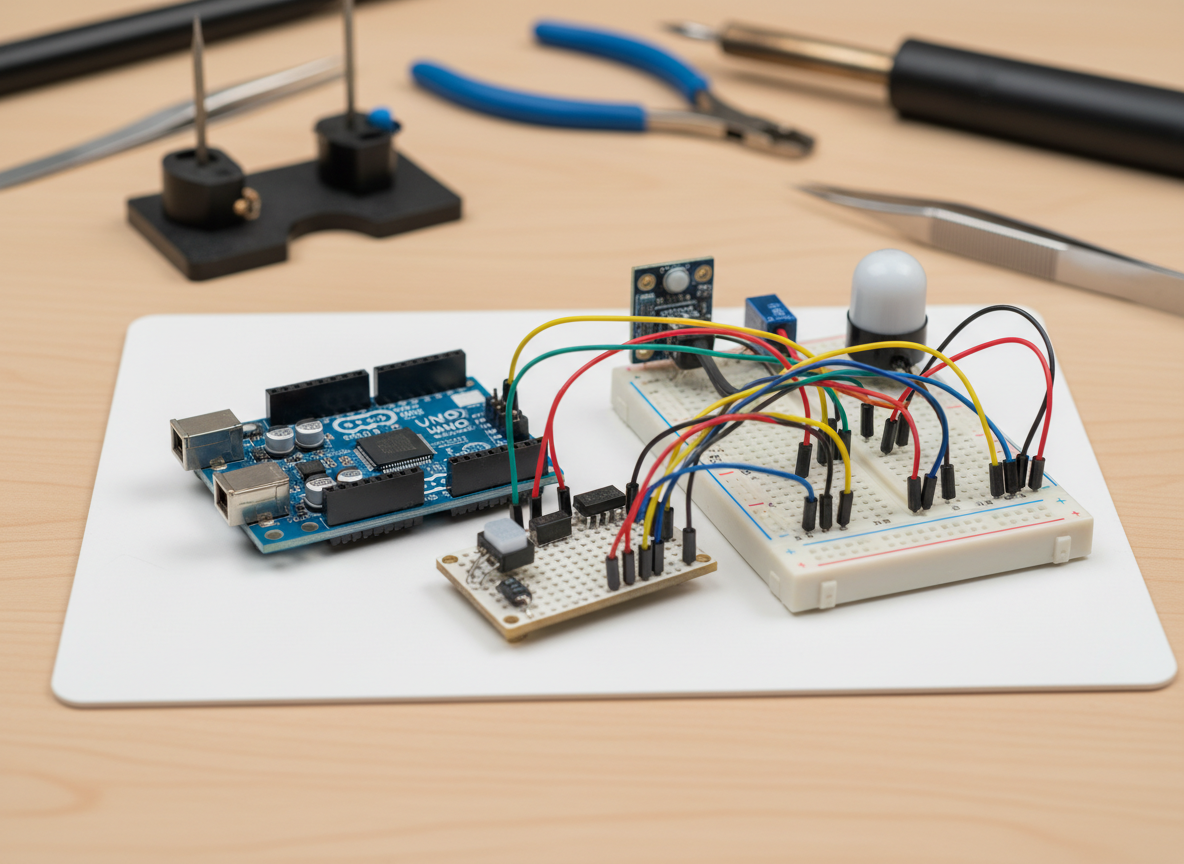
Electronics
ardunio alarm clock
An embedded system pairing an Arduino with an RTC module, 7-segment display, and buzzer. Programmed in C++ with custom alarm logic and a physical button interface for time-setting.
2024
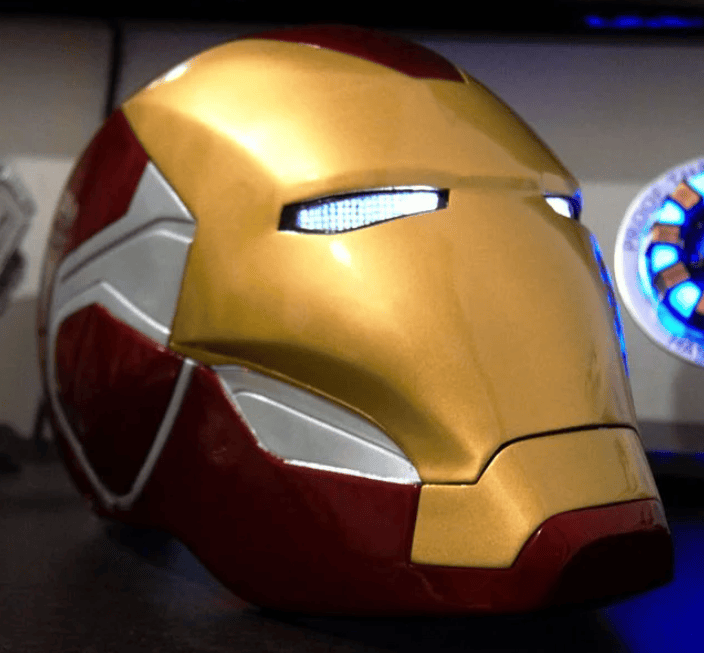
CAD Design
3D Printed Iron man helmet
A full-scale Iron Man helmet modeled in Fusion 360 and printed in PLA. Designed with split-shell construction for printability, then sanded, primed, and painted to a screen-accurate finish.
2023
robotics
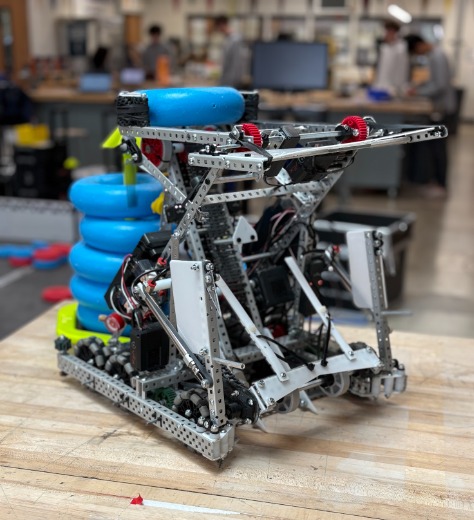
vex high stakes
A competitive robot built for VEX High Stakes, engineered for fast ring intake and reliable autonomous routines. Focused on mechanism repeatability and driver control precision.
2025
simulation
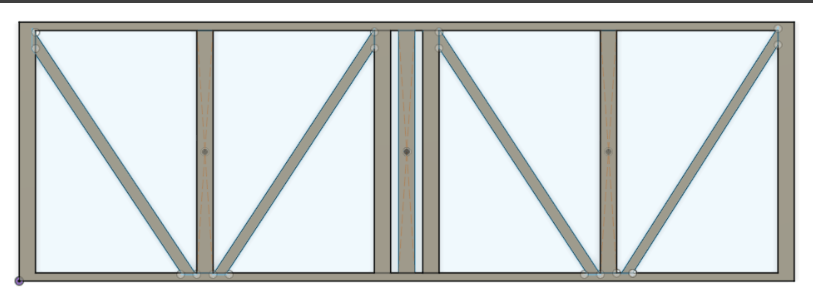
truss designs
A series of truss configurations analyzed in simulation to compare load distribution, deflection, and structural efficiency. Used to explore how geometry affects performance under static loading.
2024
robotics
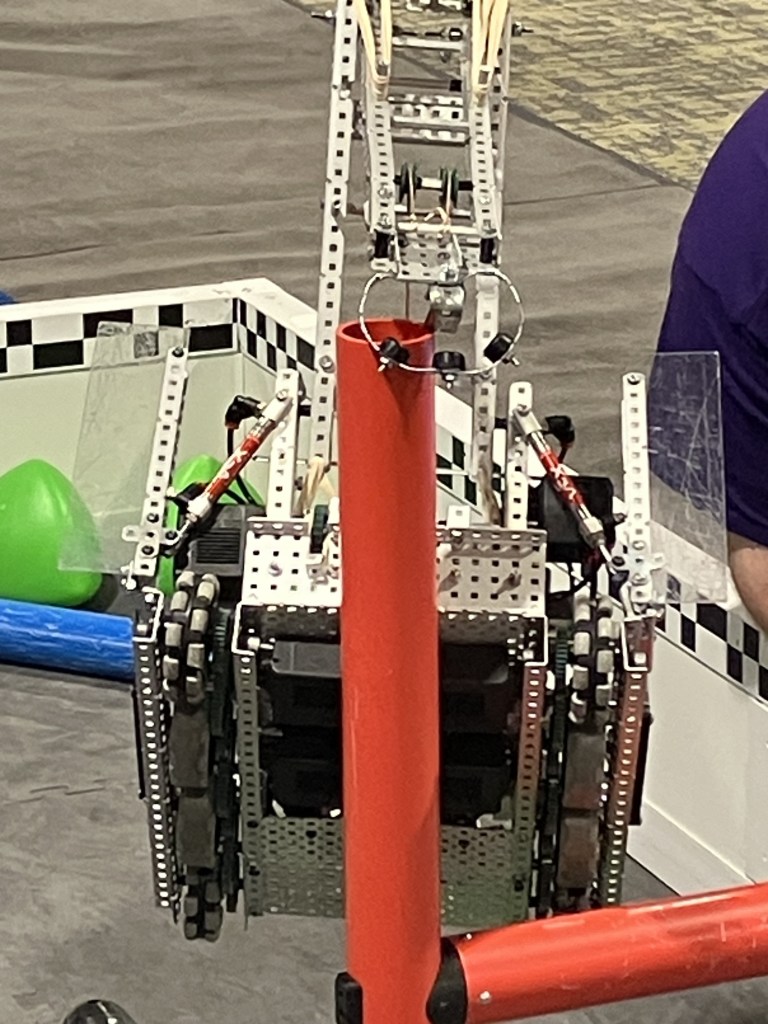
vex over under
A VEX Over Under competition robot optimized for triballing and goal coverage. Iterated through chassis and mechanism designs to maximize field control and endgame positioning.
2024
cad design
3d printed lamp
A parametric lamp designed in Fusion 360 and printed in translucent PLA. Shade geometry was tuned to diffuse light evenly while keeping the form minimal and modern.
2023
simulation
multisim
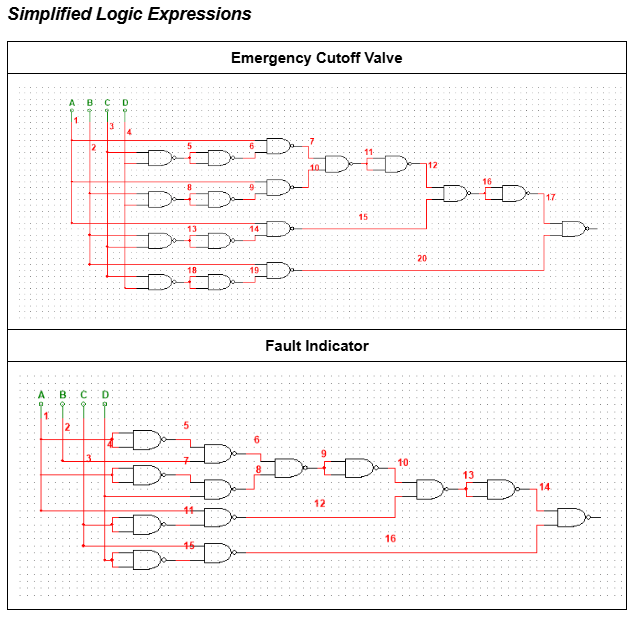
A set of circuit simulations built in Multisim to analyze voltage, current, and component behavior across various configurations. Used to validate designs before physical prototyping.
2025

